Tool short title

Vector Dot Product & Angle Calculator

Badge euclidean space

Calculate vector dot product, scalar magnitude, and angle between 2D, 3D, and N-D vectors instantly. Get step-by-step vector projections and Cauchy-Schwarz checks.

Label presets pill bar
Title regime selector
Label dimension selector3D Label space suffix
Label vector a
Label magnitude a3.7417
Label vector b
Label magnitude b1.7321
Label decimal precision4 Label decimal places
Kpi dot product
0
Kpi status zero
Kpi angle theta
90°
1.571 rad
Kpi cos similarity
0
Label cosine domain
Kpi orientation
Class orthogonal
Status zero work
Title3 d vector plane
Label yawLabel pitch
+X+Y+Za [2, 3, -1]b [1, -1, -1]
Label vector a legendLabel vector b legend
θ = 90° | cos(θ) = 0
Subhead vector metrics
Label dot product summary0
Label norm a summary3.7417
Label norm b summary1.7321
Label product norms6.4807
Subhead angular displacement
Label angle degrees90°
Label angle radians1.5708 rad
Label normalized cosine0
Label scalar comp0
Badge pure client math
Stat space dim title3D Suffix euclidean space
Stat cauchy margin titleΔ = 6.4807
Stat client executionStat client execution value

Client-Side Processing

High-performance calculation executed entirely in browser memory.

Zero Server Upload Privacy

All payloads remain strictly local with zero external server communication.

Production Ready Export

Clean, optimized output formats ready for immediate deployment.
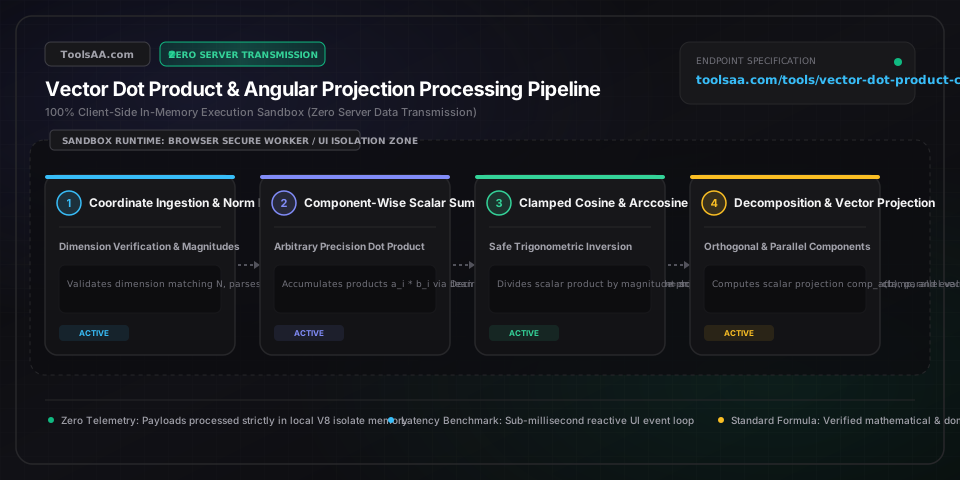
Technical Reference & Architecture Guide

Vector Dot Product & Angle Calculator Guide

Calculate vector dot product, scalar magnitude, and angle between 2D, 3D, and N-D vectors instantly. Get step-by-step vector projections and Cauchy-Schwarz checks.

Vector Dot Product & Angle Calculator Guide — Client-Side In-Memory Architecture & Data Flow

Key Parameters & Controls

Vector Coordinate Tuple AOrdered Real Coordinate Sequence [a₁, a₂, ..., aₙ]

Cartesian components along standard directional axes (x, y, z or unit vectors i, j, k). The Euclidean length (magnitude ||A||) must be strictly greater than zero to define directional orientation and evaluate angular relationships.

Default: [2, 3, -1]
Vector Coordinate Tuple BOrdered Real Coordinate Sequence [b₁, b₂, ..., bₙ]

Matching directional components across the exact same spatial dimension count N as Vector A. Both vectors must exist in identical dimensional space for paired coordinate multiplication.

Default: [1, -1, -1]
Angular Measurement UnitRotational Standard (Degrees vs Radians)

Geometric angle output format: degrees across the closed interval [0°, 180°] for intuitive visual trajectories, or radians across [0, π] for analytical physics, biomechanics, and trigonometric calculations.

Default: degrees
Reverse Target Angle SolverConstrained Angular Objective

Target benchmark angle (such as 90° for perpendicular force balance or 0° for direct alignment) used to isolate and back-solve an unknown directional component in Vector B.

Default: 90°

Pro Tips & Best Practices

Floating-Point Clamping Prevents Arccosine NaN Crashes

Due to microscopic computational rounding in decimal division, the inner product ratio (a · b) / (||a|| × ||b||) can occasionally evaluate to 1.0000000000000002 for parallel paths. Because standard arccosine is strictly undefined outside the closed domain [-1.0, 1.0], calculators crash with a NaN (not-a-number) error unless the cosine quotient is clamped between -1.0 and +1.0 prior to angular conversion.

Distinguish Scalar Component From Vector Projection

A scalar projection comp_a(b) produces a single signed number indicating the shadow length cast along vector a, whereas the vector projection proj_a(b) is a full directed arrow with both length and orientation. Calculate vector projection directly using proj_a(b) = ((a · b) / ||a||²) × a to eliminate error-prone compounding of intermediate square roots.

Zero Vector Boundary Condition Is Indeterminate

If either vector has all zero components [0, 0, ...], the dot product mathematically equals 0, but the spatial angle between them is undefined (indeterminate) rather than a true 90° right angle. Perpendicularity strictly requires two non-zero vectors with distinct physical headings.

Common Gotchas & Troubleshooting

⚠️Angle returns NaN or error when vectors are parallel or antiparallel

Microscopic rounding artifacts in numerical calculations can push the cosine ratio fractionally beyond +1.0 or below -1.0. Apply an explicit boundary clamp constraining the quotient strictly within [-1.0, 1.0] before evaluating the inverse cosine.

⚠️Dot product evaluates to zero but vectors do not appear perpendicular

Verify whether either input has a magnitude of zero. While any dot product involving a stationary origin point [0, 0, 0] evaluates to zero, true geometric orthogonality requires both vectors to possess non-zero directional magnitudes.

⚠️Mismatched dimension error when entering vector coordinates

Vector dot products require identical dimension counts in both sequences. Ensure that both vectors have the exact same number of directional values and that extra commas or empty spaces do not create accidental phantom axes.

Frequently Asked Questions

How to calculate the dot product of two vectors?▼

Multiply matching coordinates from each vector pairwise and sum the individual products: a · b = (a₁ × b₁) + (a₂ × b₂) + ... + (aₙ × bₙ). For example, given 2D vectors a = [2, 3] and b = [4, -1], calculate (2 × 4) + (3 × -1) = 8 + (-3) = 5. A positive scalar sum indicates that both directions generally face the same hemisphere.

How do you find the angle between two vectors using the dot product formula?▼

Divide the dot product by the product of both vector lengths and take the inverse cosine: θ = arccos((a · b) / (||a|| × ||b||)). For vectors a = [3, 4] (length 5) and b = [4, 3] (length 5) with a dot product of 24, calculate cos(θ) = 24 / (5 × 5) = 0.96, yielding θ = arccos(0.96) ≈ 16.26°. The resulting geometric angle always lies strictly between 0° (collinear) and 180° (opposing).

What is the difference between the dot product and the cross product?▼

The dot product produces a single scalar value representing directional alignment across any dimensional space (2D, 3D, or N-D), whereas the cross product produces a perpendicular 3D vector measuring rotational torque and enclosed parallelogram area. Dot products evaluate how much two vectors cooperate along the same line; cross products evaluate the perpendicular twist between them exclusively in three dimensions.

Can the vector dot product be negative, and what does it mean?▼

Yes, a negative dot product indicates that the spatial angle between the two vectors is obtuse (strictly between 90° and 180°). In biomechanics and motion analysis, a negative dot product between an applied muscular force vector and a movement displacement vector signifies resistive or eccentric braking work, where force directly opposes forward motion.

Related Tools & Utilities

All Tools →