Header title

Vector Cross Product Calculator (3D & Area)A × B

Calculate 3D vector cross product A × B with step-by-step 3×3 determinant expansion, real-time 3D interactive visualizer, unit normal vector, parallelogram area, and orthogonality verification.

Lbl quick presets

Title vector a

Lbl norm a 0.5000

Title vector b

Lbl norm b 128.1601
Title precision settings
Title target solver||A × B|| = S

Desc target solver

Kpi cross vector
(0, -22.5000, 60.0000)
Lbl magnitude: 64.0800
Kpi parallelogram area
64.0800
Lbl triangle area: 32.0400
Kpi included angle
90.0000°
Lbl dot product: 0
Kpi geometric state
Status orthogonal
Hint right hand rule
Lbl drag rotateBadge right hand
Legend vector aLegend vector bLegend cross product
100%
Stat exact calculations
Stat drift free
Stat spatial orthogonality
Stat perpendicular verified
Stat zero server upload
Stat zero leak

Client-Side Processing

High-performance calculation executed entirely in browser memory.

Zero Server Upload Privacy

All payloads remain strictly local with zero external server communication.

Production Ready Export

Clean, optimized output formats ready for immediate deployment.
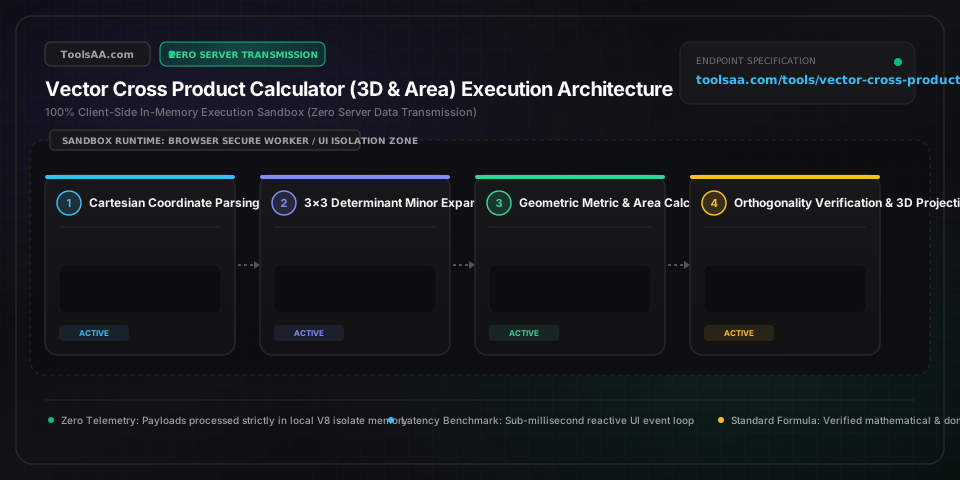
Technical Reference & Architecture Guide

Vector Cross Product Calculator (3D & Area) Guide

Calculate 3D vector cross product A × B with step-by-step 3×3 determinant expansion, real-time 3D interactive visualizer, unit normal vector, parallelogram area, and orthogonality verification.

Vector Cross Product Calculator (3D & Area) Guide — Client-Side In-Memory Architecture & Data Flow

Key Parameters & Controls

Vector A Components (a_x, a_y, a_z)3D Coordinate Vector

Spatial coordinate projections along the orthogonal standard basis axes (i, j, k) in 3D Euclidean space. In physical dynamics, these quantify directional quantities such as lever-arm displacement (meters) or translational velocity (m/s). Values can range across all real numbers (-∞ to +∞).

Default: [1, 2, 3]
Vector B Components (b_x, b_y, b_z)3D Coordinate Vector

Secondary directional coordinate set representing interacting physical forces (Newtons), magnetic fields (Tesla), or structural triangle edges. Cross multiplication evaluates the mutual perpendicular torque or enclosed spatial surface generated with Vector A.

Default: [4, 5, 6]
Included Planar Angle (θ)Angular Measure (Degrees / Radians)

Subtended interior angle between Vector A and Vector B, bounded strictly within [0°, 180°] (0 to π radians). Cross product magnitude peaks at θ = 90° (perpendicular alignment where sin(θ) = 1) and collapses to zero when vectors become collinear (parallel at 0° or anti-parallel at 180°).

Default: 32.18°
Unit Normal Vector (n̂)Normalized Directional Vector

Pure directional unit vector perpendicular to the mutual plane formed by A and B, defined as (A × B) / ||A × B|| with a fixed norm of 1.0. Used in aerodynamic lofting, robotic arm trajectory planning, and computer rendering to orient perpendicular surface planes.

Default: [-0.408, 0.816, -0.408]

Pro Tips & Best Practices

Right-Hand Rule Verification Method

Point the index finger of your right hand along Vector A and curl your middle finger toward Vector B through the smallest interior angle (≤ 180°). Your outstretched thumb points in the exact direction of A × B. If you reverse the operand order to B × A, your thumb flips 180° in the opposite direction due to anti-commutativity.

Eliminating Collinear Floating-Point Zero Drift

When calculating cross products for parallel vectors (such as [1, 2, 3] and [2, 4, 6]), standard binary computer precision creates tiny phantom residuals like 1e-16 instead of 0. Always apply an epsilon zero-clamp threshold (< 1e-12) to ensure collinear vectors collapse cleanly into an exact null vector (0, 0, 0).

Counter-Clockwise Winding for 3D Surface Normals

In 3D CAD modeling and game physics, consistently construct triangle edge vectors in counter-clockwise order: set Vector A = Vertex1 - Vertex0 and Vector B = Vertex2 - Vertex0. Normalizing A × B produces an outward-facing surface normal, preventing invisible inside-out polygons and backface culling render glitches.

Instant Triangle and Parallelogram Area Extraction

The Euclidean magnitude ||A × B|| directly equals the total surface area of the parallelogram spanned by both vectors. To compute the exact surface area of the planar triangle formed by connecting their tips to the origin, simply divide the magnitude by 2: Area_triangle = 0.5 × ||A × B||.

Common Gotchas & Troubleshooting

⚠️Resulting cross product vector is (0, 0, 0) and Unit Normal shows undefined

A null cross product occurs whenever vectors are collinear (parallel with θ = 0° or opposing with θ = 180°), or if either input is a zero vector (0, 0, 0). When lines run parallel, sin(θ) = 0 and the enclosed parallelogram collapses to zero area, making it impossible to define a unique perpendicular surface normal.

⚠️Cross product vector points 180° in the exact opposite direction expected

Vector cross products are strictly anti-commutative: B × A = -(A × B). Swapping the operand input sequence flips every directional sign. Reverse the input order back from B to A, or take the negative reciprocal vector -(B × A) to recover the intended right-handed normal.

Frequently Asked Questions

How to calculate the cross product of two 3D vectors?▼

To calculate the cross product A × B of vectors A = (ax, ay, az) and B = (bx, by, bz), expand the 3×3 determinant across standard basis unit vectors: A × B = (ay·bz - az·by)i - (ax·bz - az·bx)j + (ax·by - ay·bx)k. For example, crossing [1, 2, 3] with [4, 5, 6] yields (2·6 - 3·5)i - (1·6 - 3·4)j + (1·5 - 2·4)k = (-3, 6, -3), producing a 3D vector strictly perpendicular to both input vectors.

What is the difference between dot product and cross product?▼

The dot product (A · B = ||A|| ||B|| cos θ) yields a single scalar real number measuring directional alignment, while the cross product (A × B = ||A|| ||B|| sin θ n̂) outputs an orthogonal 3D vector measuring rotational torque and surface area. Furthermore, dot product equals zero when vectors are perpendicular (90°), whereas cross product equals zero when vectors are parallel (0° or 180°).

Why is vector cross product anti-commutative?▼

Vector cross products are anti-commutative because swapping operand order reverses rotational orientation under the right-hand rule, yielding B × A = -(A × B). In linear algebra, interchanging two rows in a 3×3 determinant multiplies the resulting determinant value by -1, which flips the signs of all three spatial components along the x, y, and z axes.

What does a cross product of zero mean?▼

A cross product of zero (0, 0, 0) means the two vectors are collinear (sharing parallel θ = 0° or anti-parallel θ = 180° directional lines) or at least one vector has a length of zero. Because the magnitude ||A × B|| = ||A|| ||B|| sin(θ) depends on sin(θ), zero angle eliminates all perpendicular separation, collapsing the enclosed parallelogram area to zero.

Can cross product be calculated in 2D or 4D spaces?▼

A true vector cross product that takes two vectors and produces a unique perpendicular vector exists exclusively in 3-dimensional space (and 7-dimensional space via octonions). In 2D space, the cross product is calculated as a 2D determinant scalar (ax·by - ay·bx) representing the z-axis magnitude of an embedded 3D plane; in 4D space, the operation generalizes to the exterior wedge product (A ∧ B), producing a 2-dimensional plane element (bivector) rather than a single vector line.

How do you find the area of a parallelogram using cross product?▼

The area of a parallelogram spanned by vectors A and B equals the Euclidean magnitude of their cross product: Area = ||A × B|| = sqrt(cx² + cy² + cz²), where C = A × B. For a triangle formed by the same two vectors, divide that magnitude in half: Area_triangle = 0.5 × ||A × B||.

Related Tools & Utilities

All Tools →
Queuing Theory Calculator (Erlang C & M/M/c)math

Industrial-grade queuing theory calculator implementing M/M/1, M/M/c (Erlang C), M/M/c/K (finite buffer), and M/M/c/c (Erlang B loss system) models. Calculate server utilization, delay probability, average wait time (Wq), queue length (Lq), and Service Level Agreement (SLA) percentages. Features automated reverse goal staffing solver, agent shrinkage adjustments, economic cost optimization, dynamic sensitivity matrices, and side-by-side A/B architecture comparison workbench.

Open tool→
Beer Priming Sugar & Carbonation CalculatorUtility

Calculate exact beer priming sugar weights in grams and ounces for dextrose, sucrose, DME, and honey with bottle burst pressure safety and syringe dosing.

Open tool→
Landed Cost & Import Unit Cost Calculatorfinance

Calculate total landed cost and per-unit import cost with duty, ocean freight, customs brokerage, insurance, and harbor fees. Solve target profit margins instantly.

Open tool→
Customs Duty Calculator & Import Tarifffinance

Calculate exact customs duty, import tariff, VAT/GST, and landed cost for US, EU, UK, and CA. Includes FOB vs CIF rules, de minimis limits, and Section 301 fees.

Open tool→
Cap Rate Calculator & Real Estate NOIfinance

Institutional-grade real estate cap rate and NOI valuation calculator for commercial and residential properties. Features itemized pro-forma operating expense ledgers, reverse target acquisition solvers, mortgage debt leverage metrics (Cash-on-Cash, DSCR, break-even occupancy), dynamic 2D price-to-yield sensitivity matrices, and one-click PDF/Excel deal exports.

Open tool→
ROAS Calculator & Break-Even Target ROASfinance

Calculate ROAS, break-even target ROAS, and net ad profit instantly. Model ad spend, gross margin, blended CAC, and required conversion rates for eCommerce ROI.

Open tool→